Vision-guided pick & place
- Role
- Design, build & programming
- Context
- Personal project
- Year
- 2026 — ongoing
- Tools
Overview
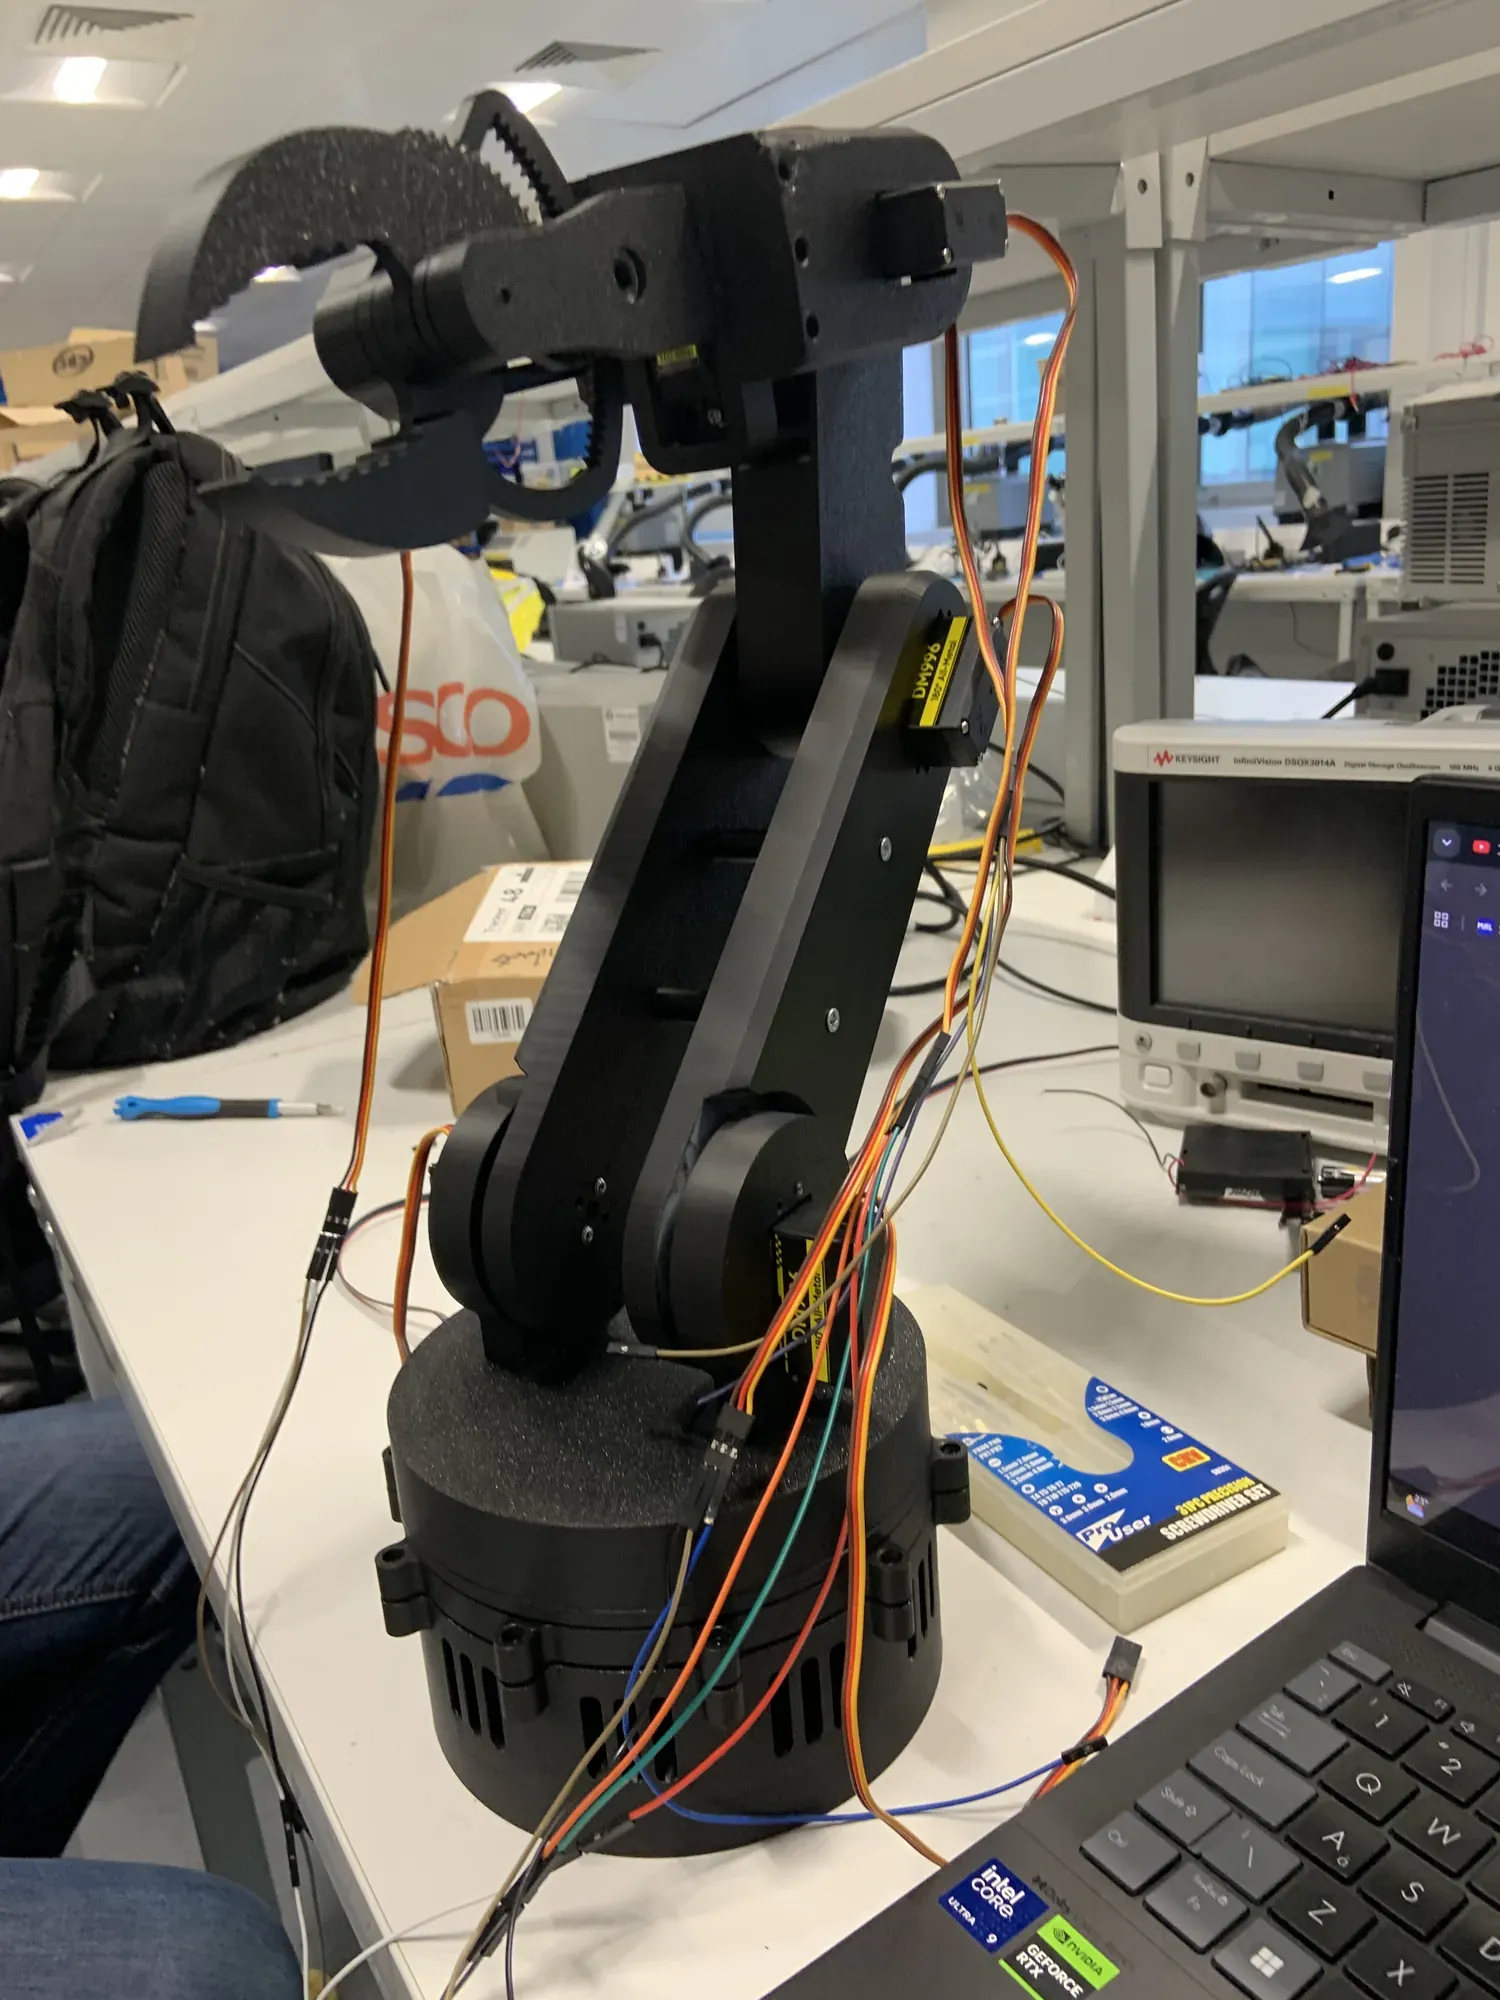
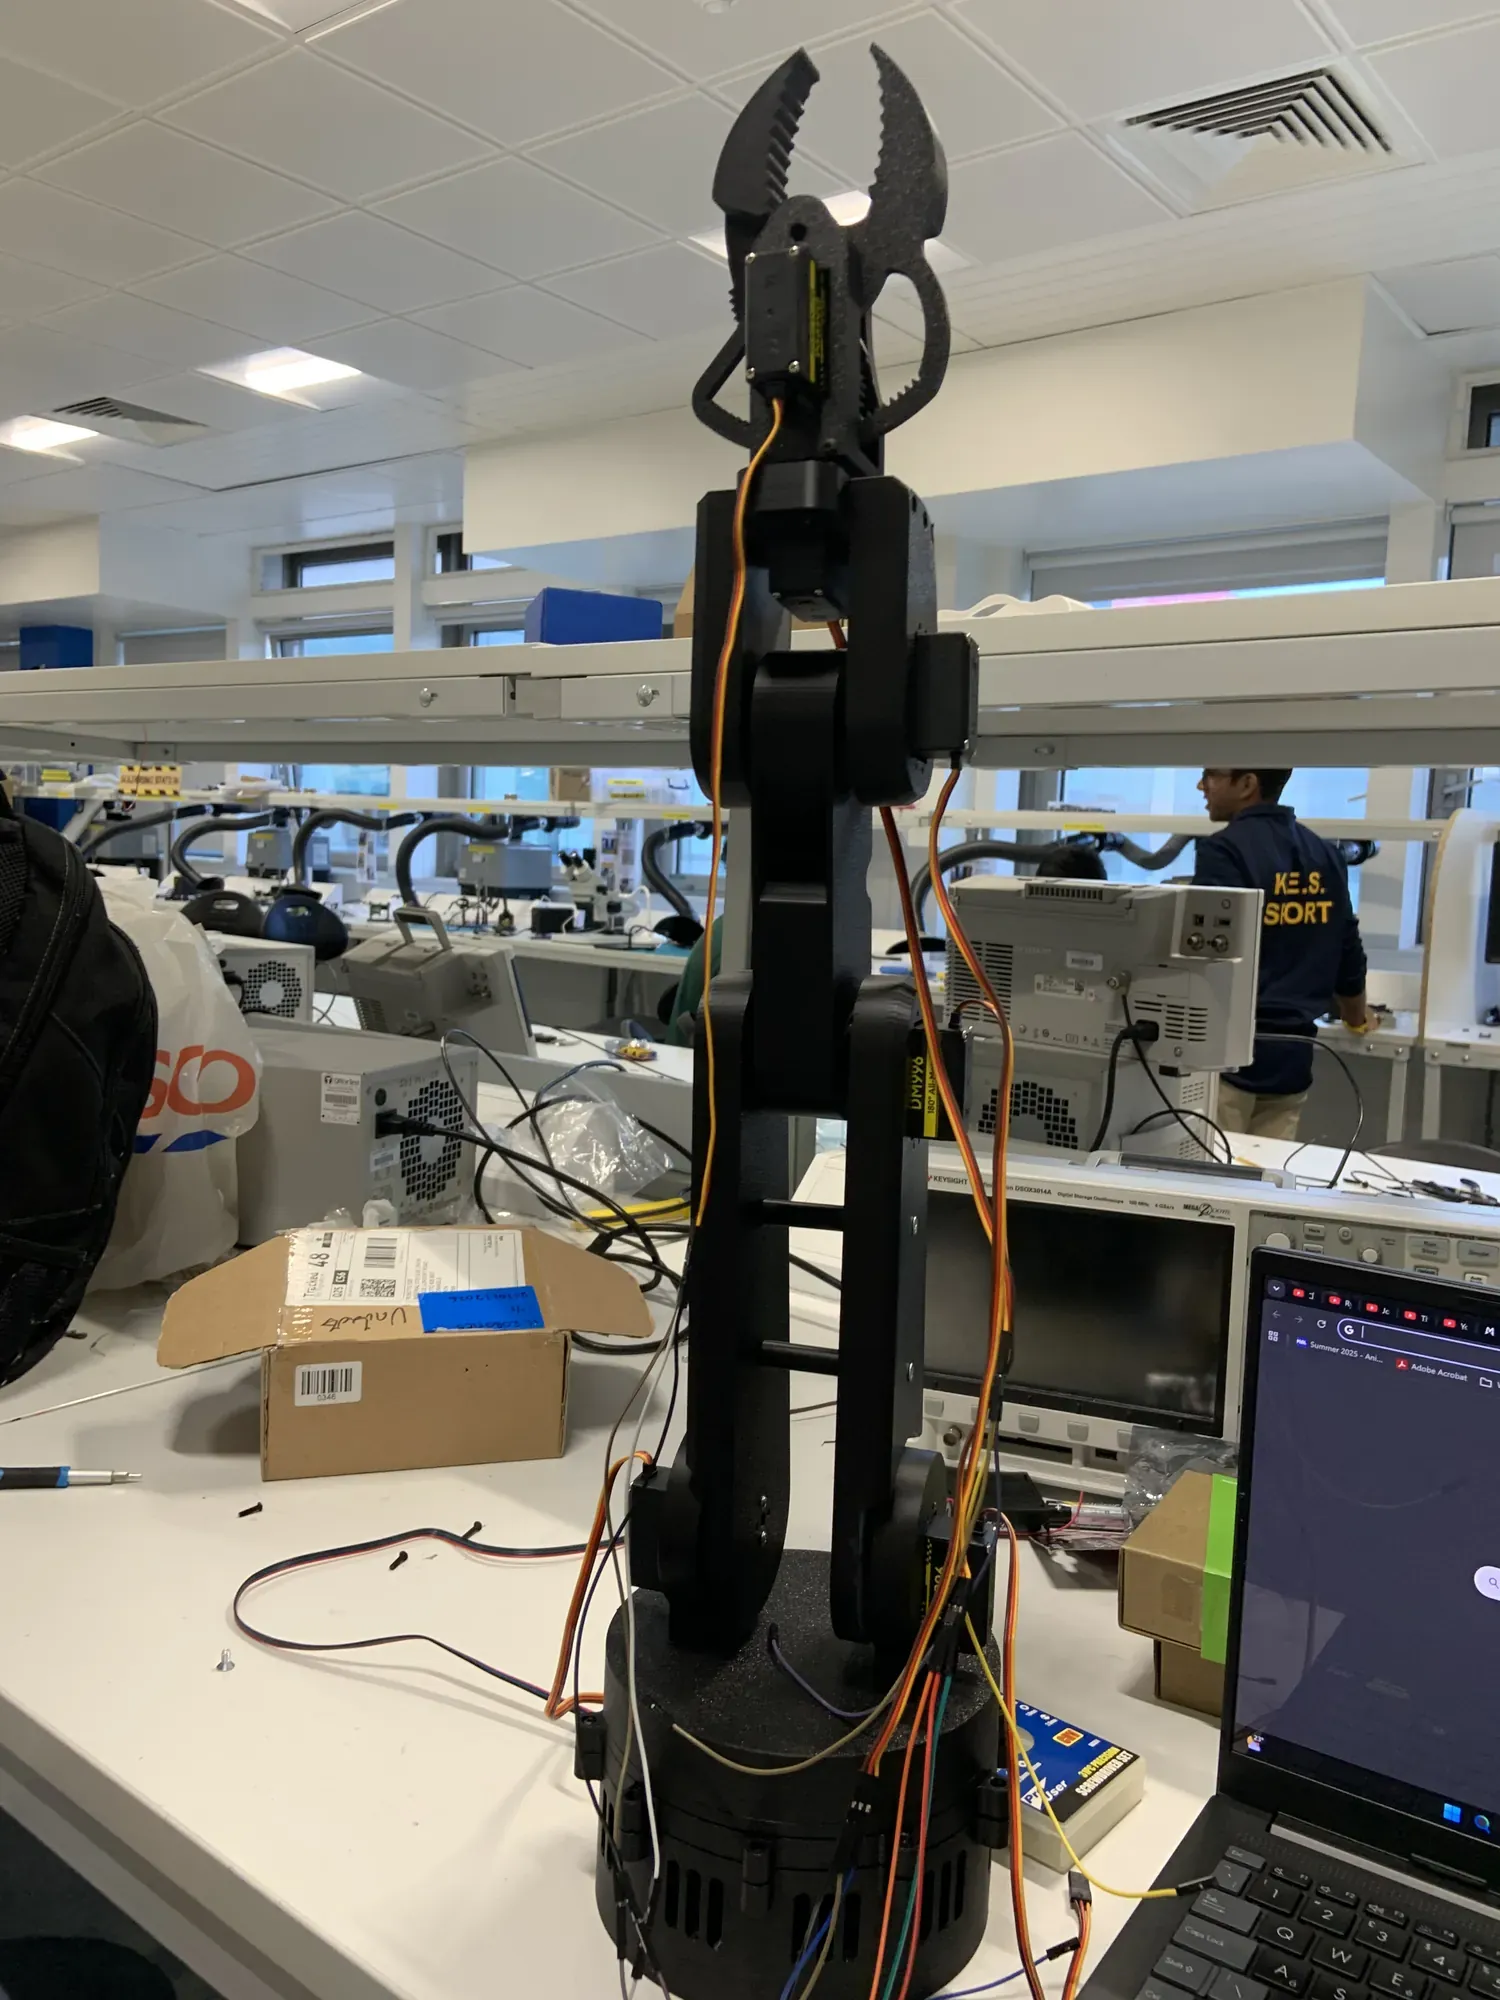
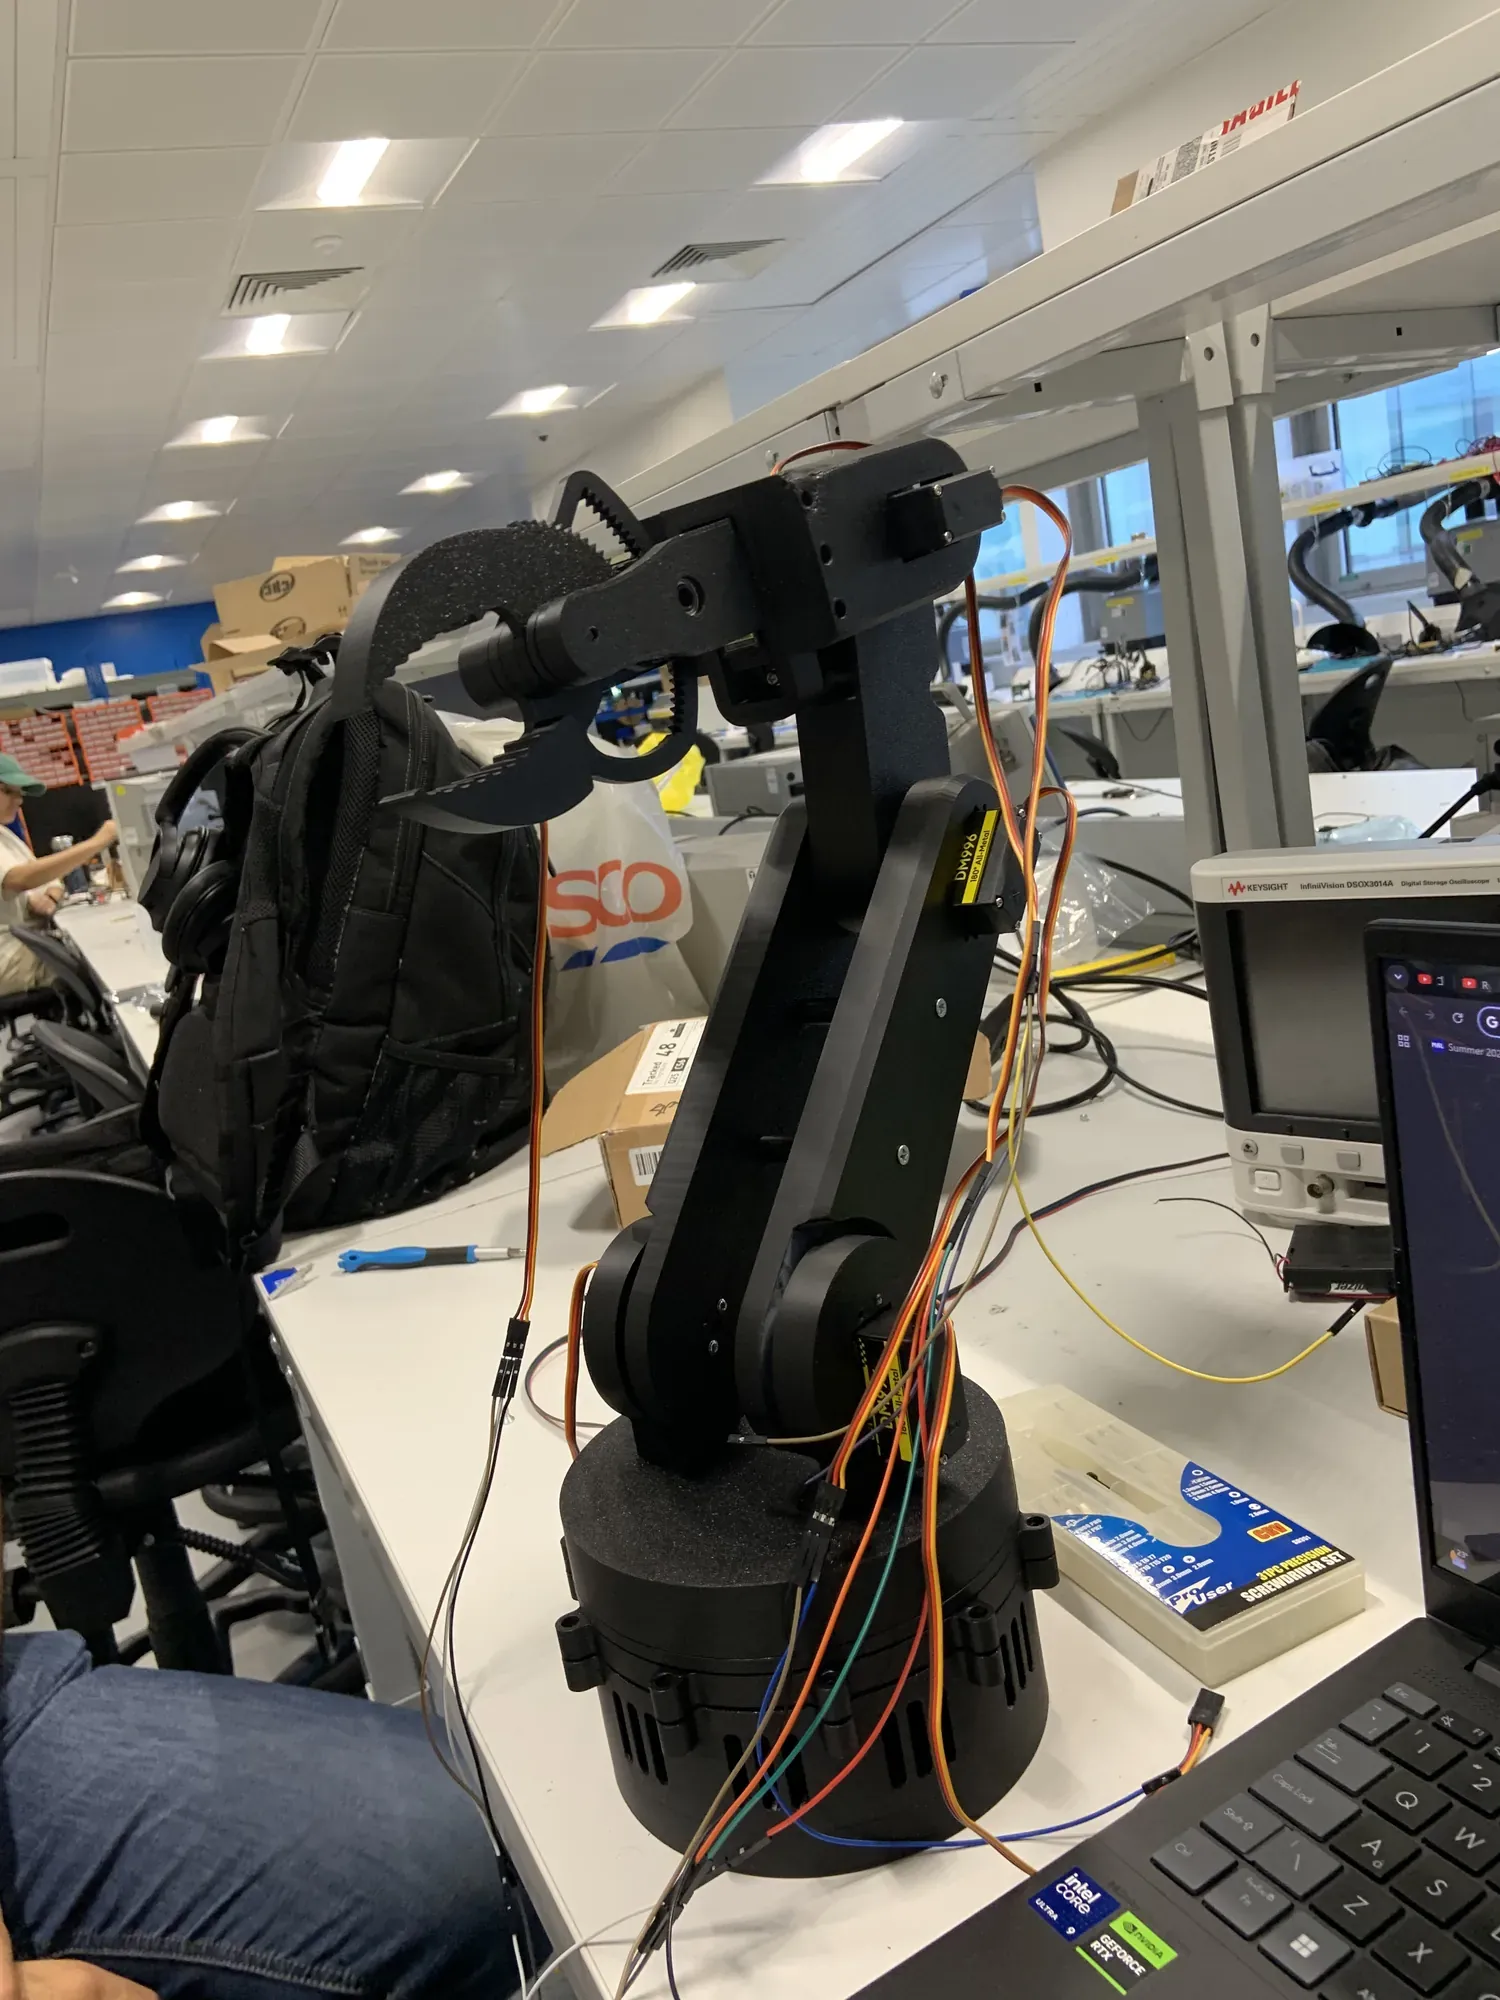
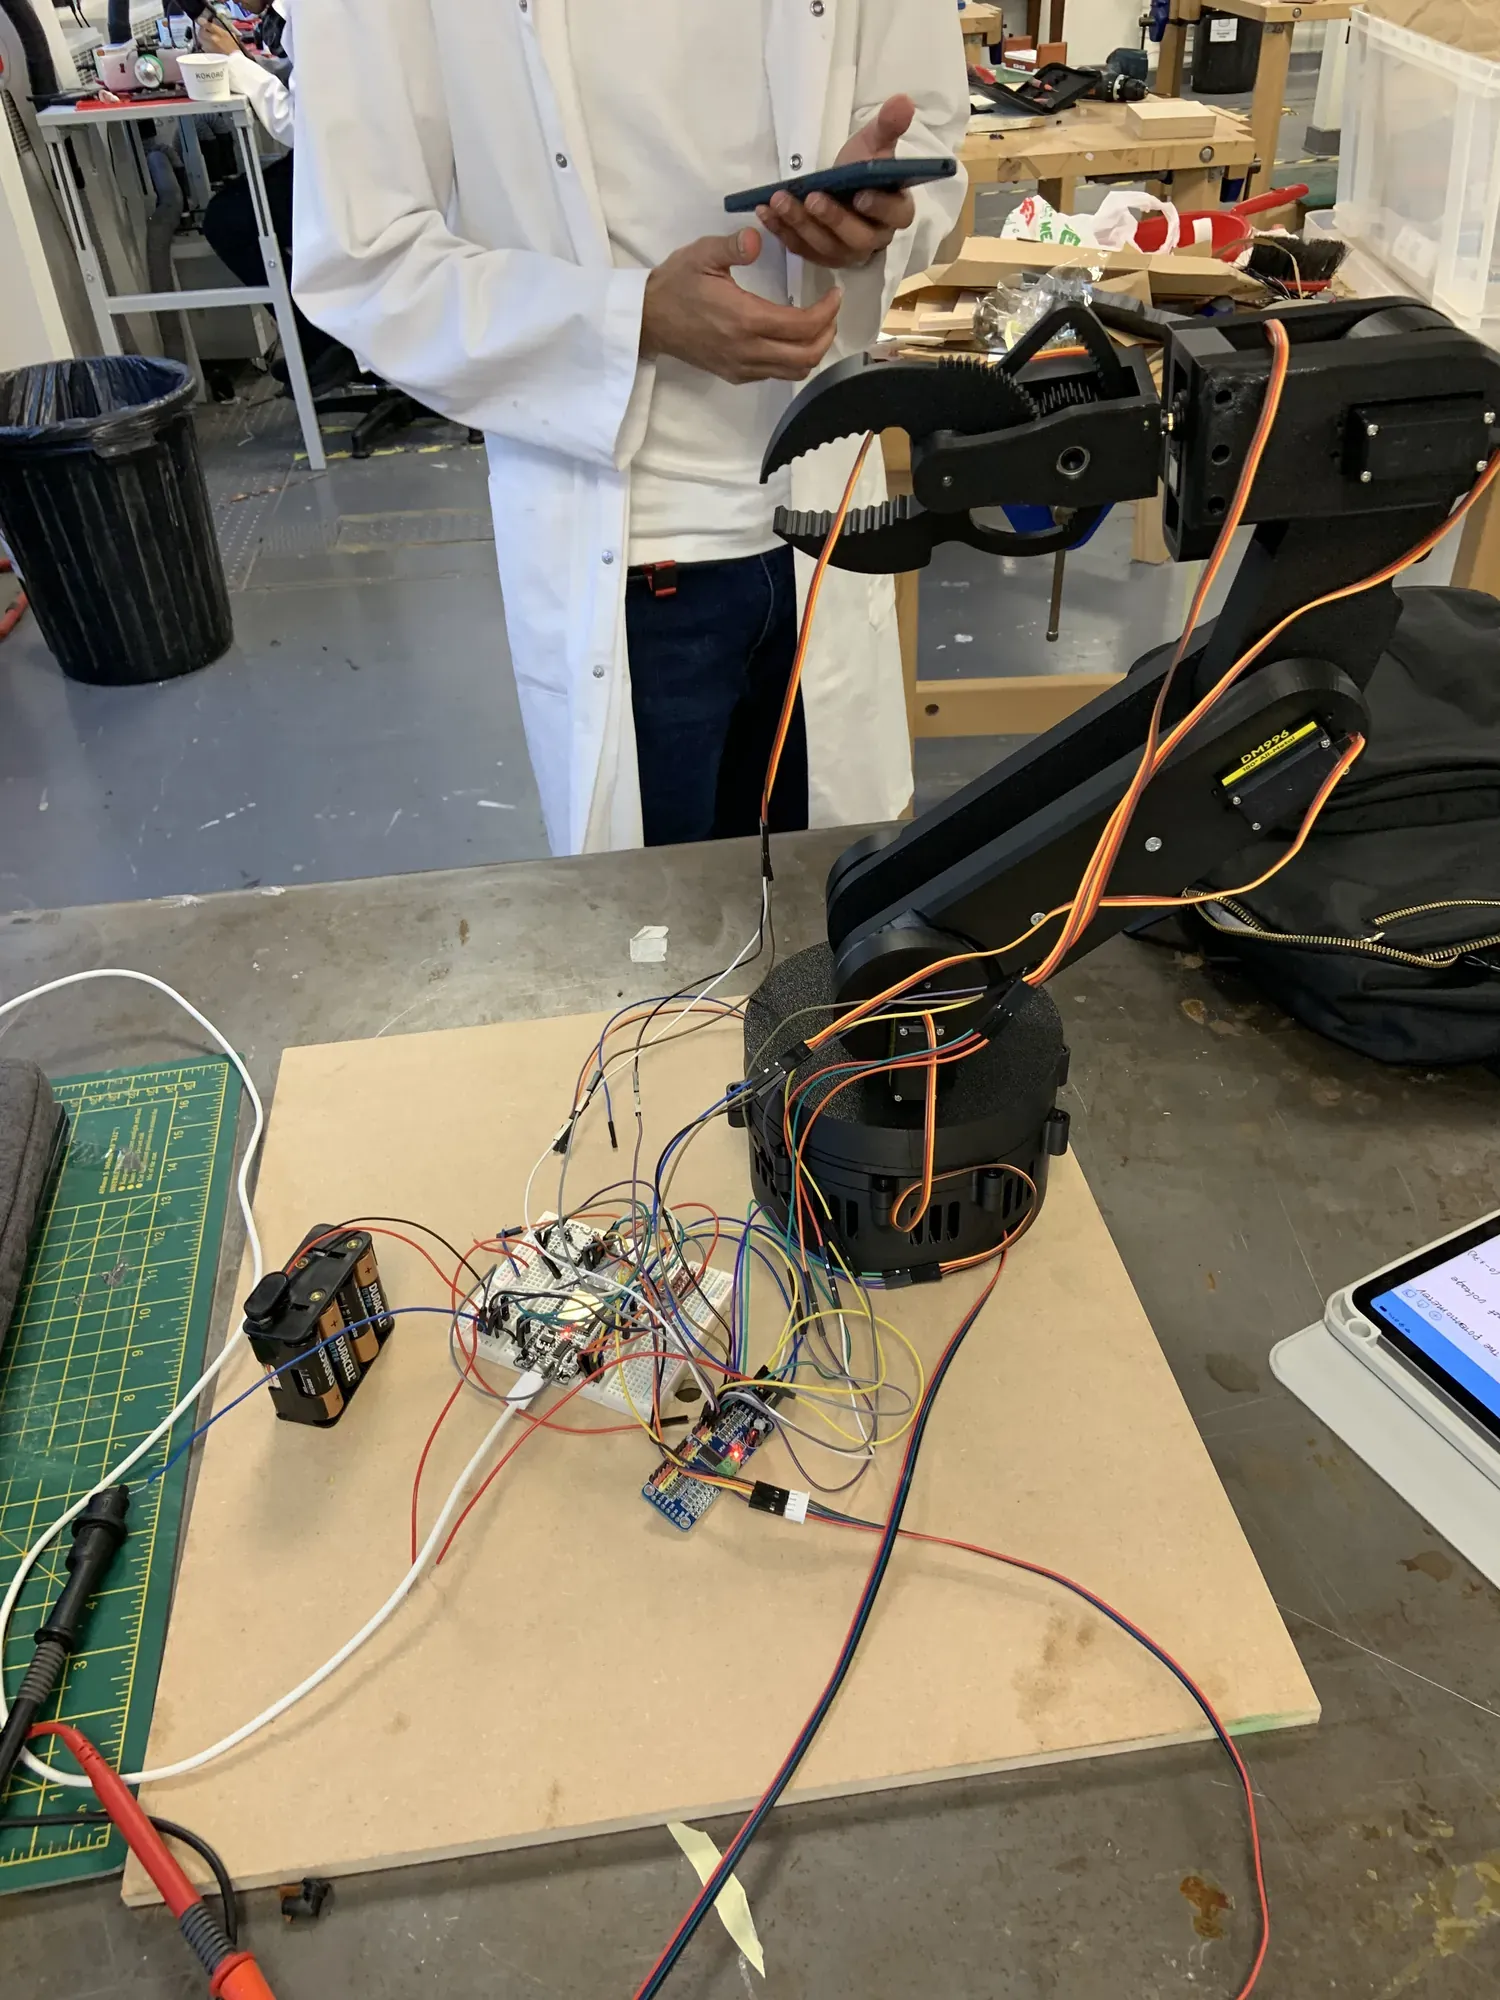
I designed and built a 6-axis robot arm that picks up coloured blocks and sorts them into zones. I use it to research PID control loops and machine learning for robotics.
6Axes of motion
MLComputer vision for colour sorting
PIDClosed-loop joint control
▶ Movement of the robot arm using a phone app
01
Build
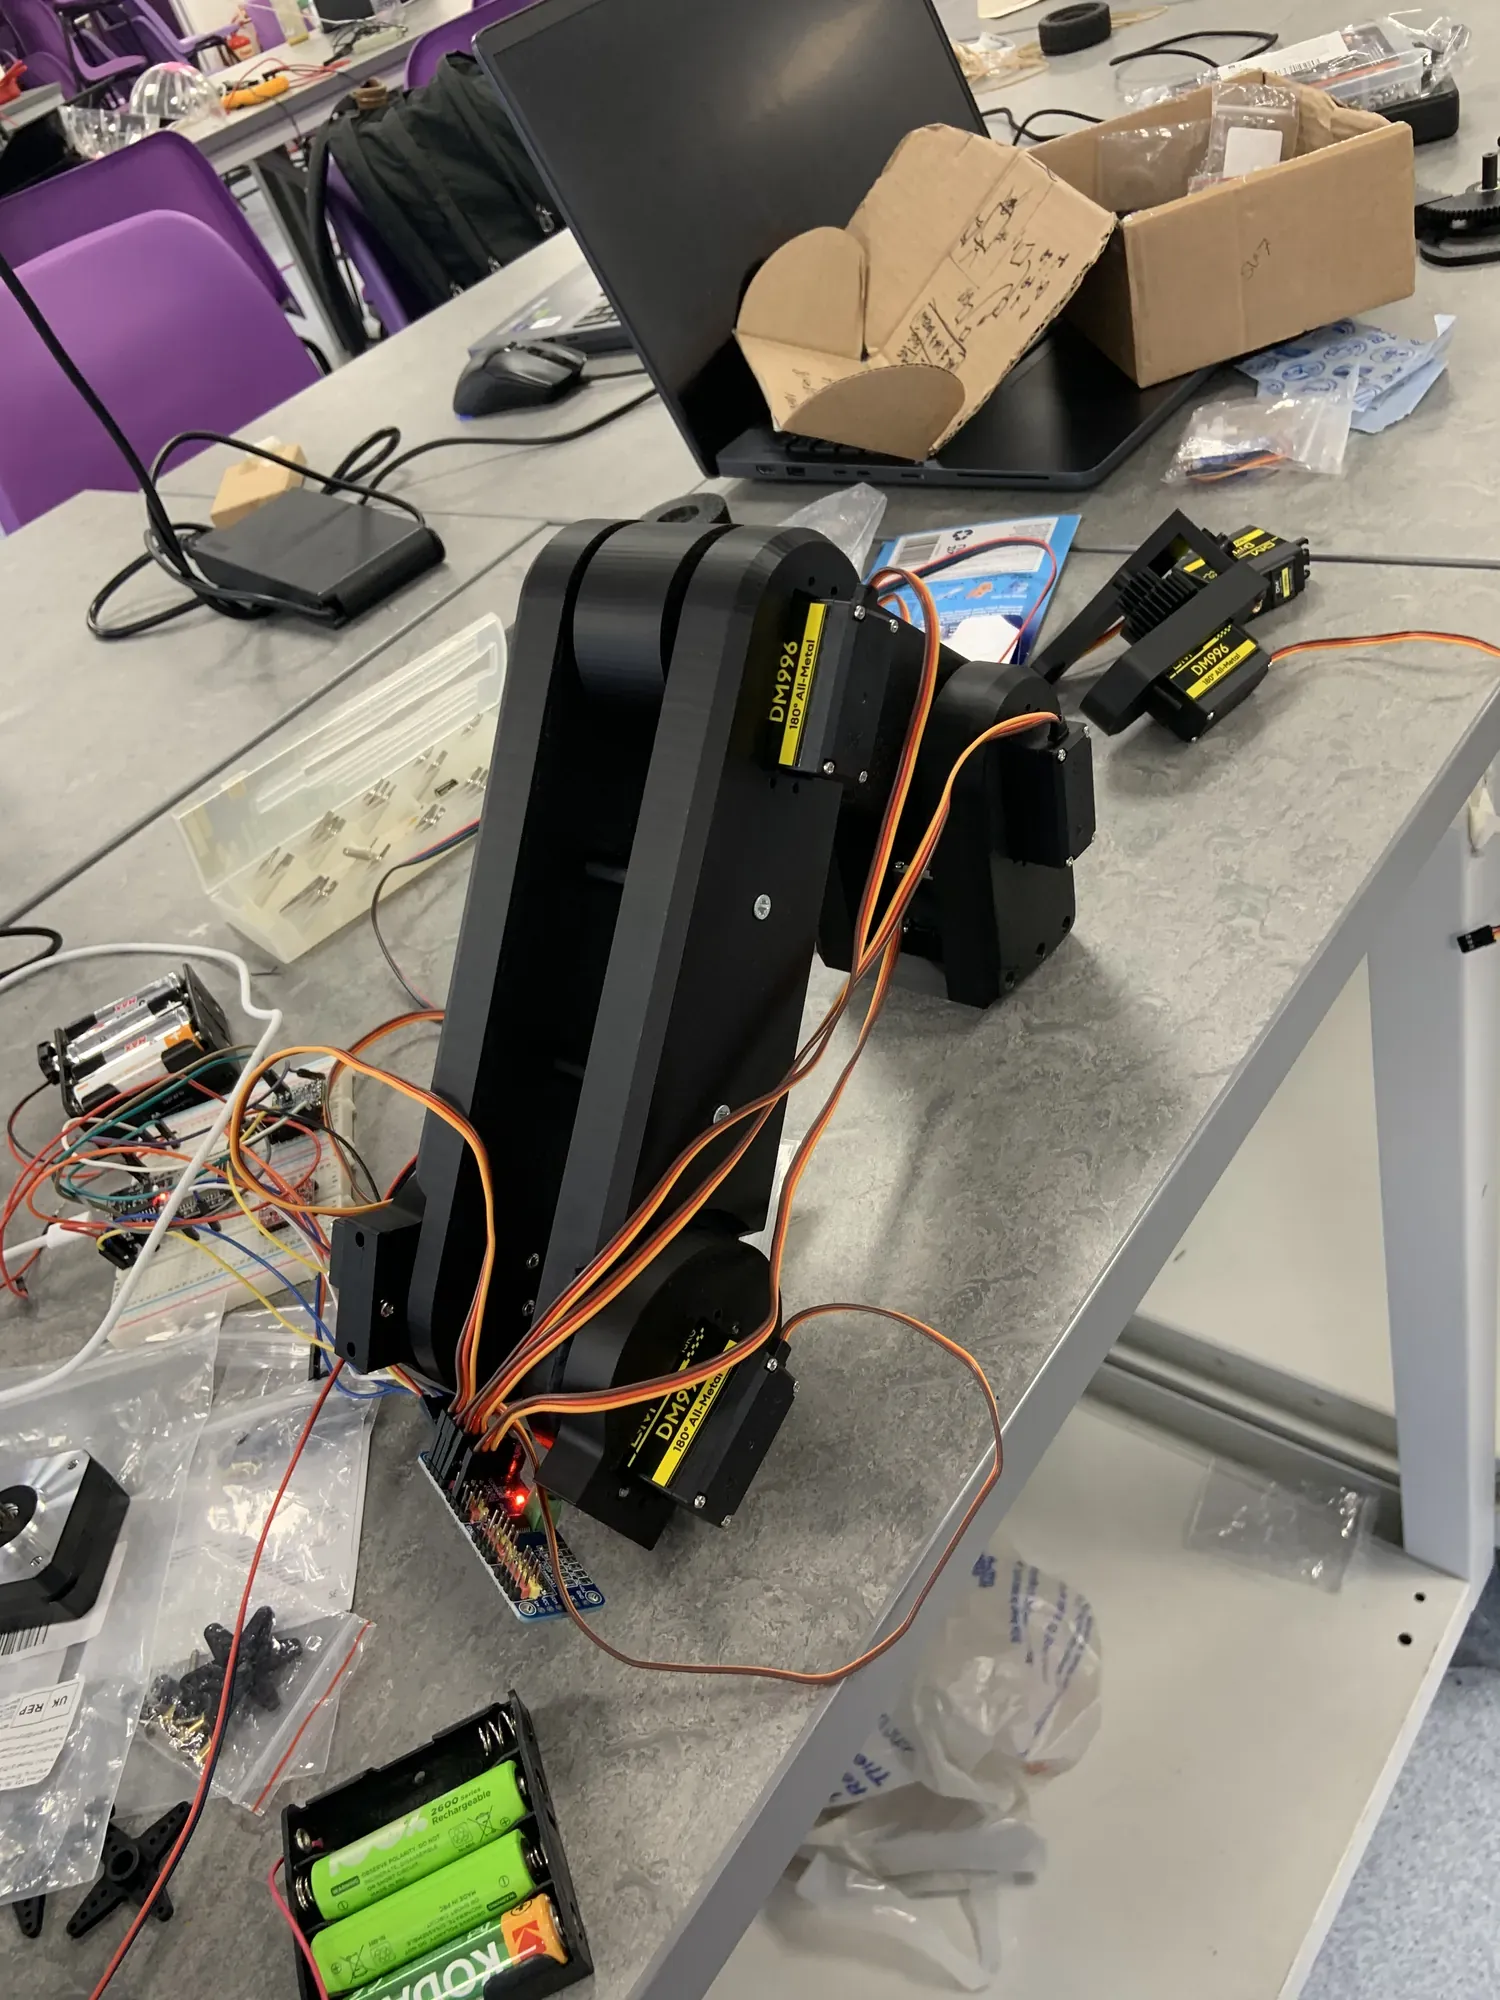
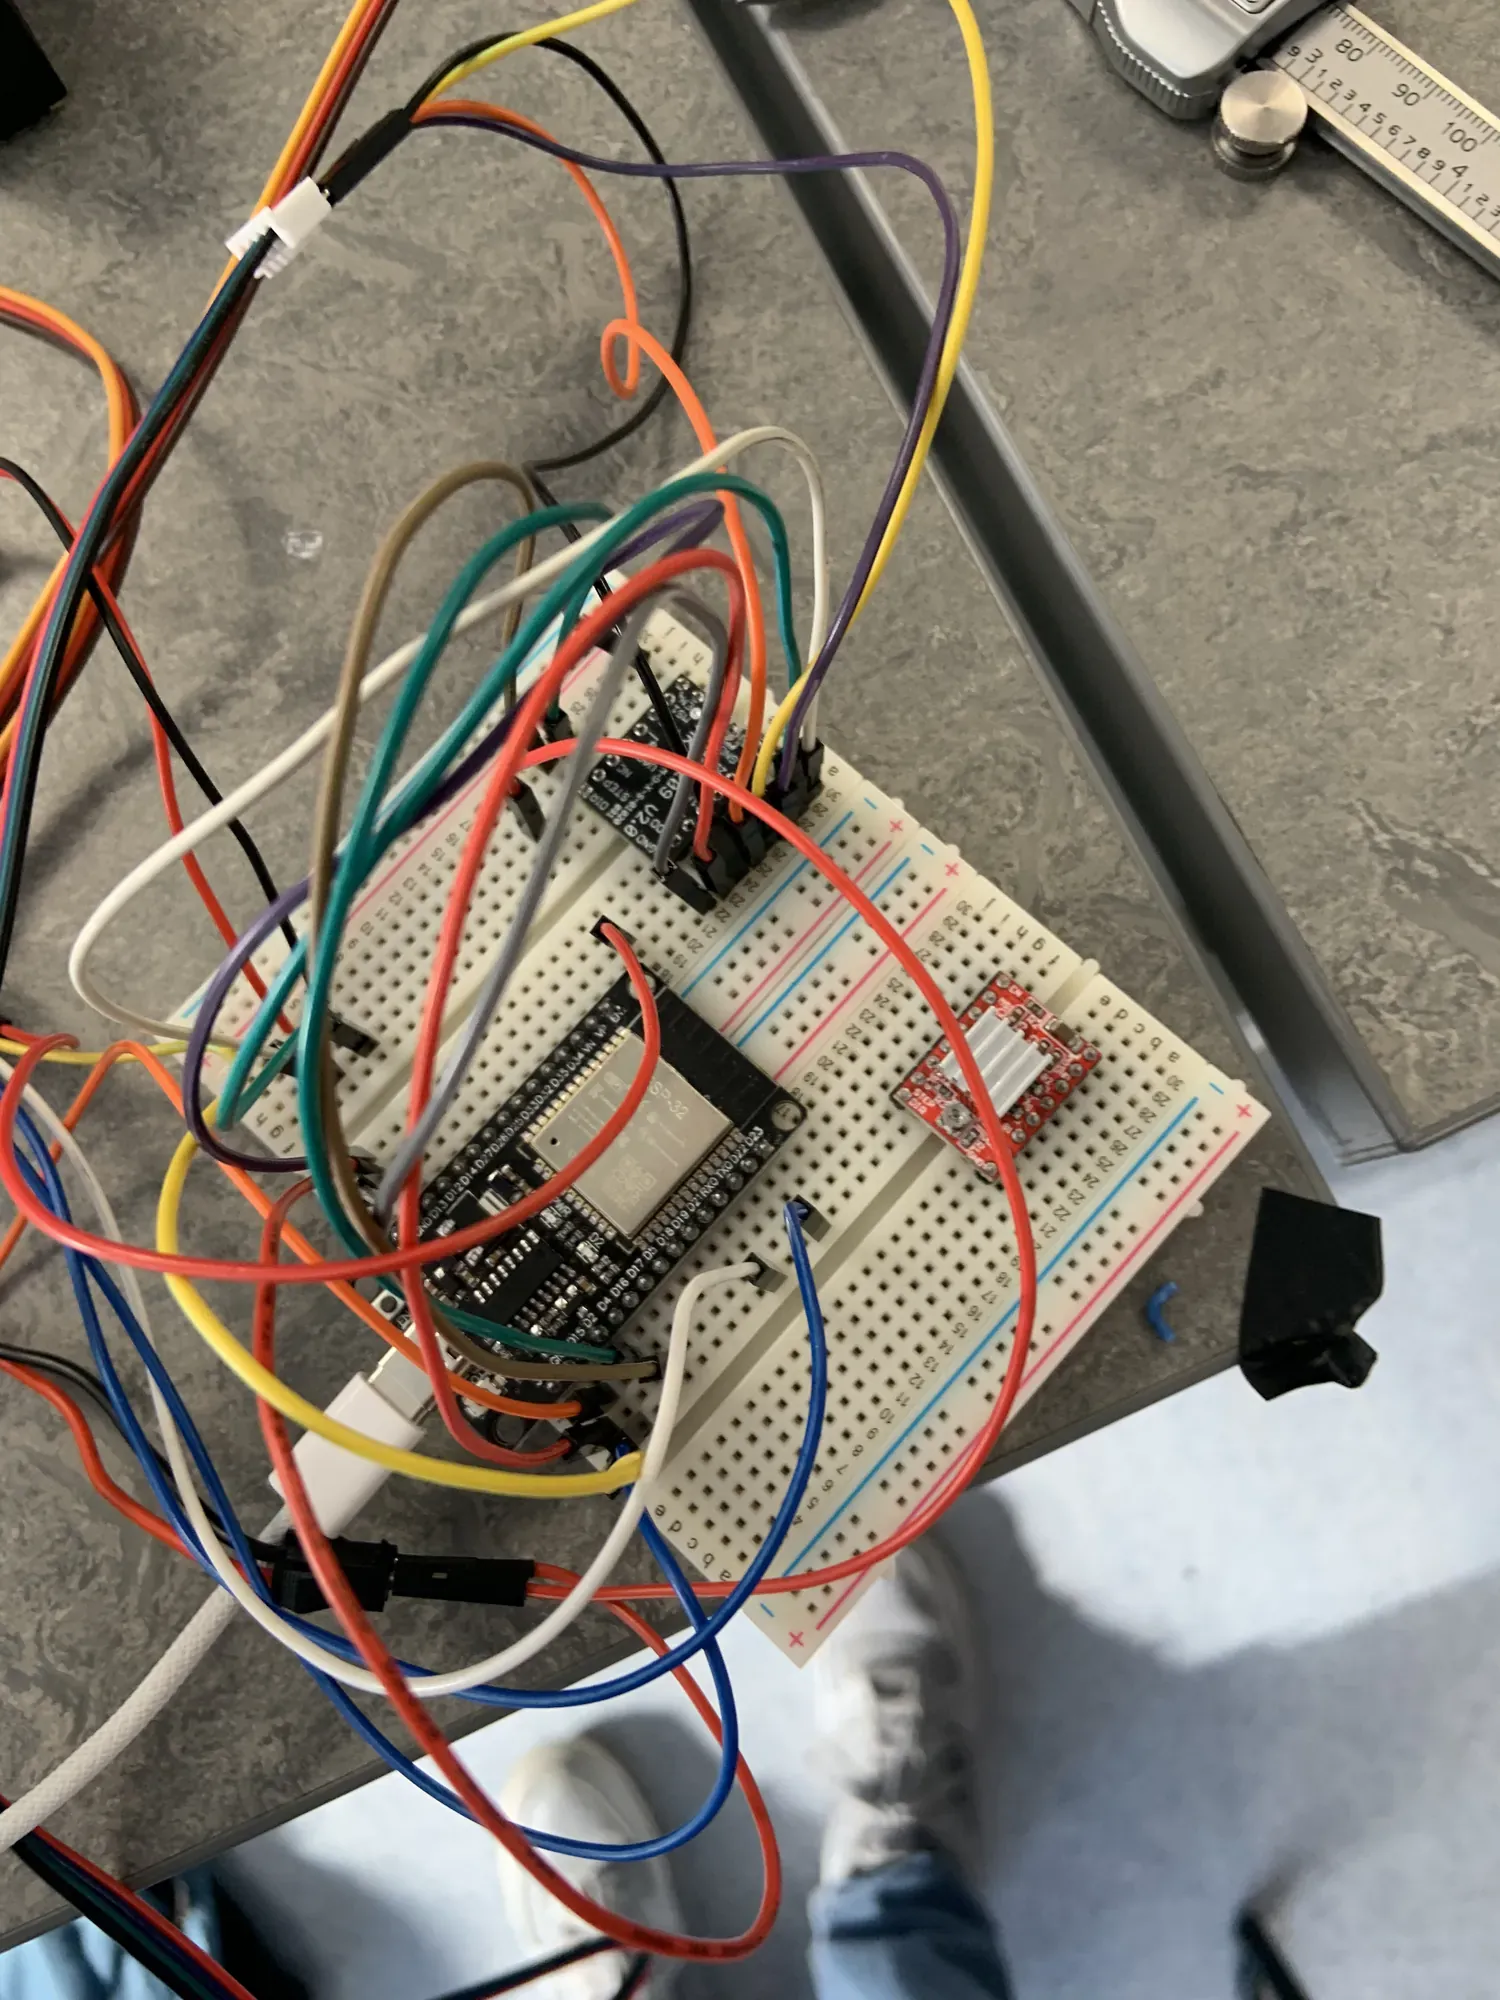
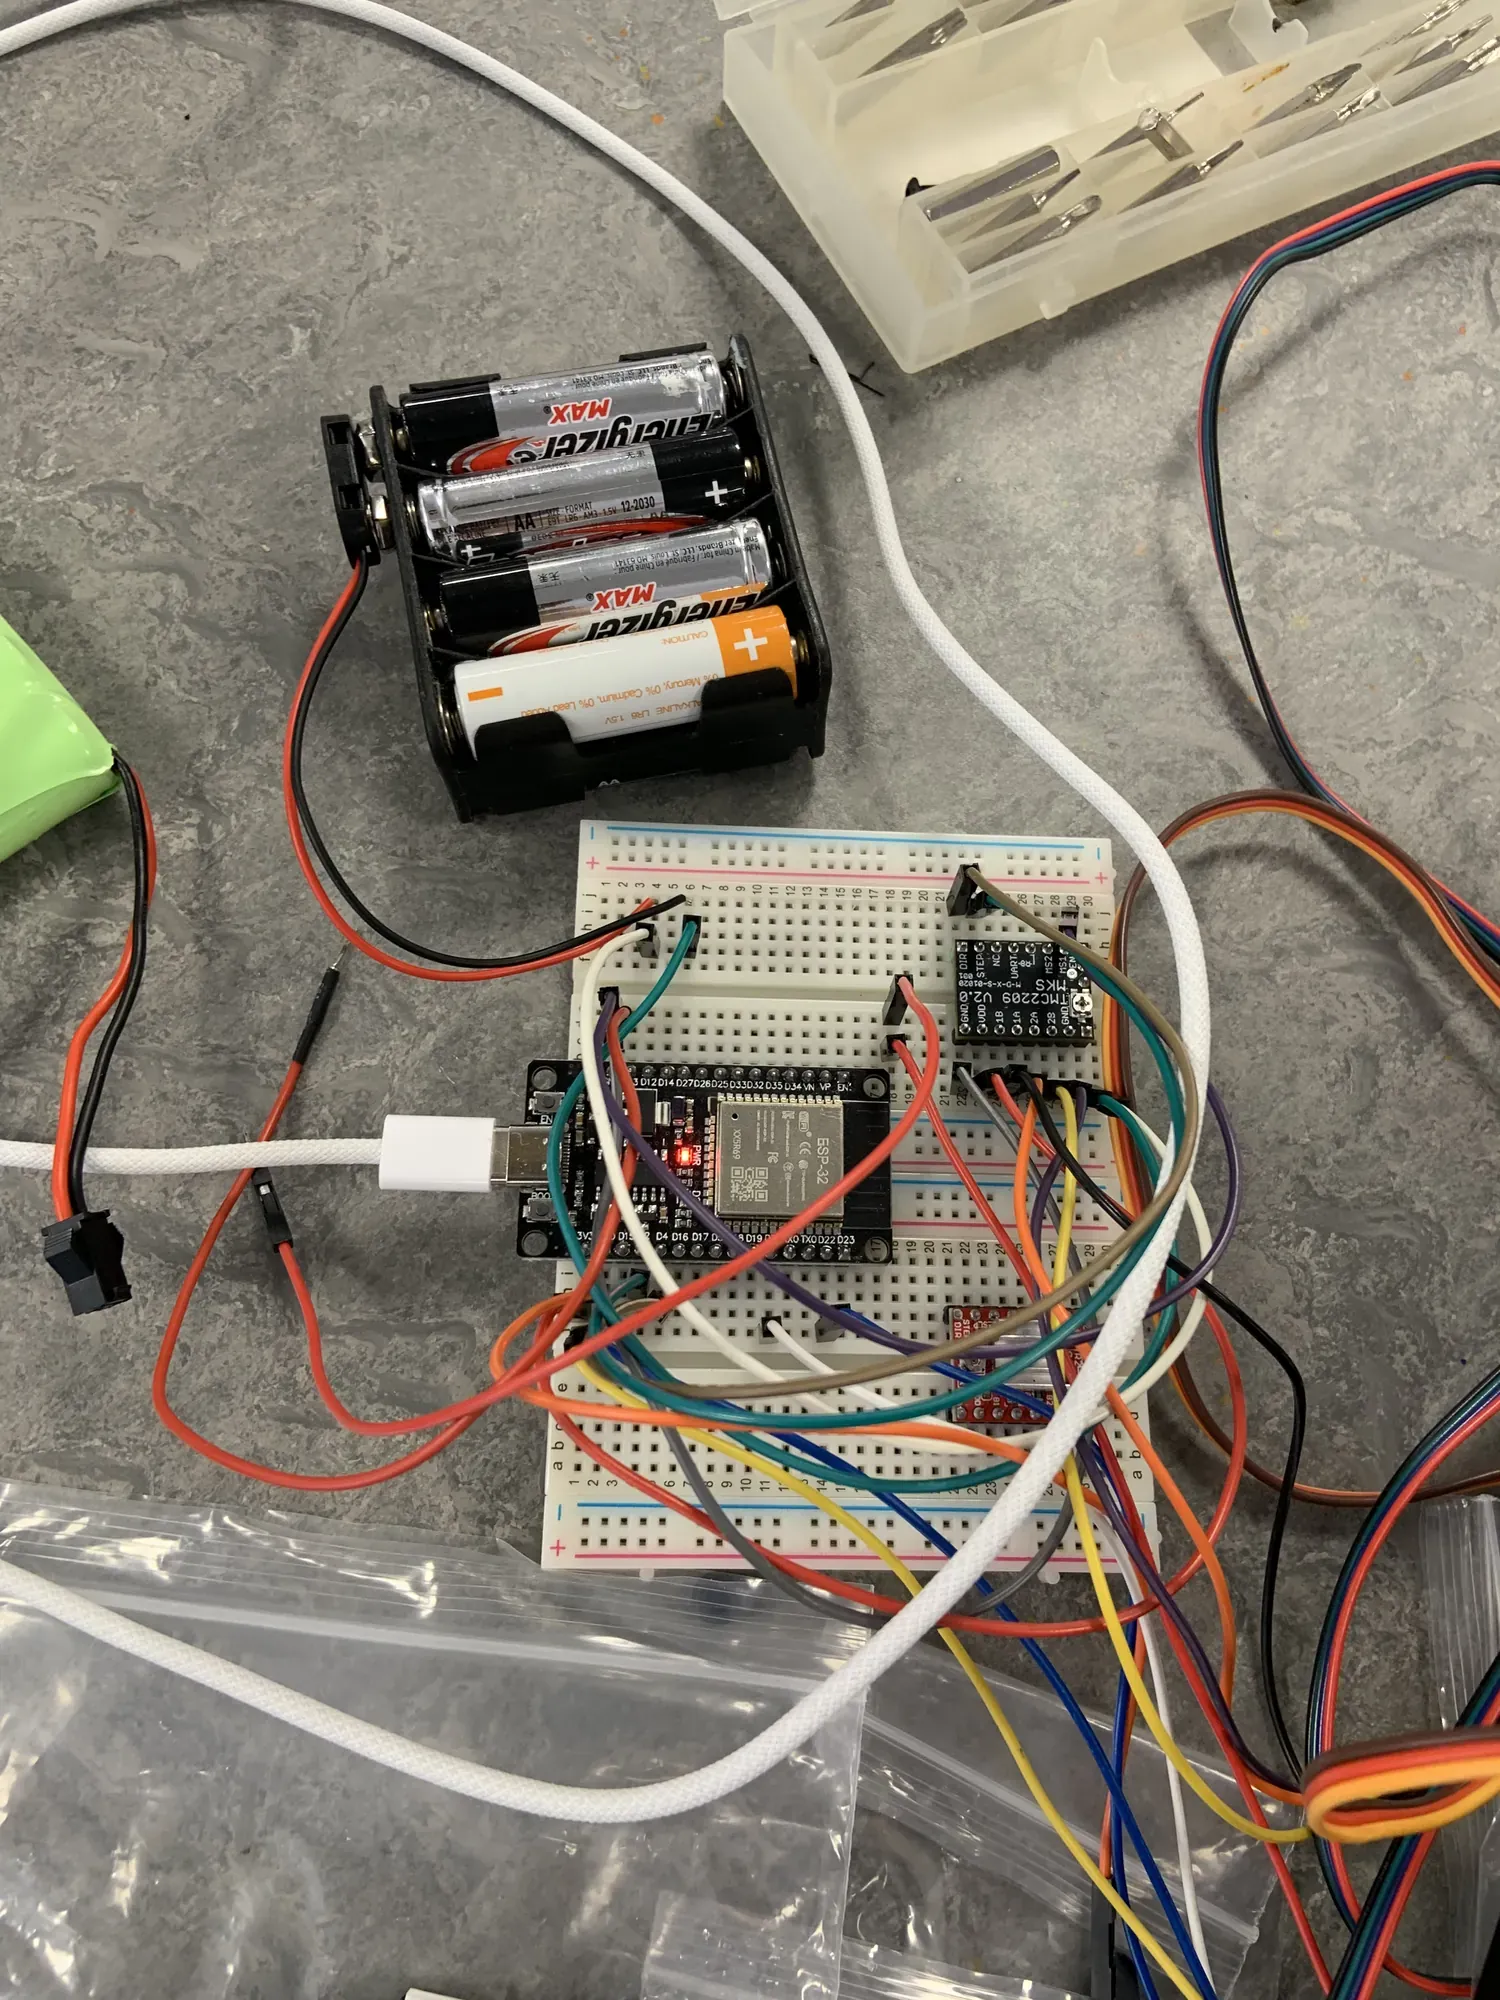
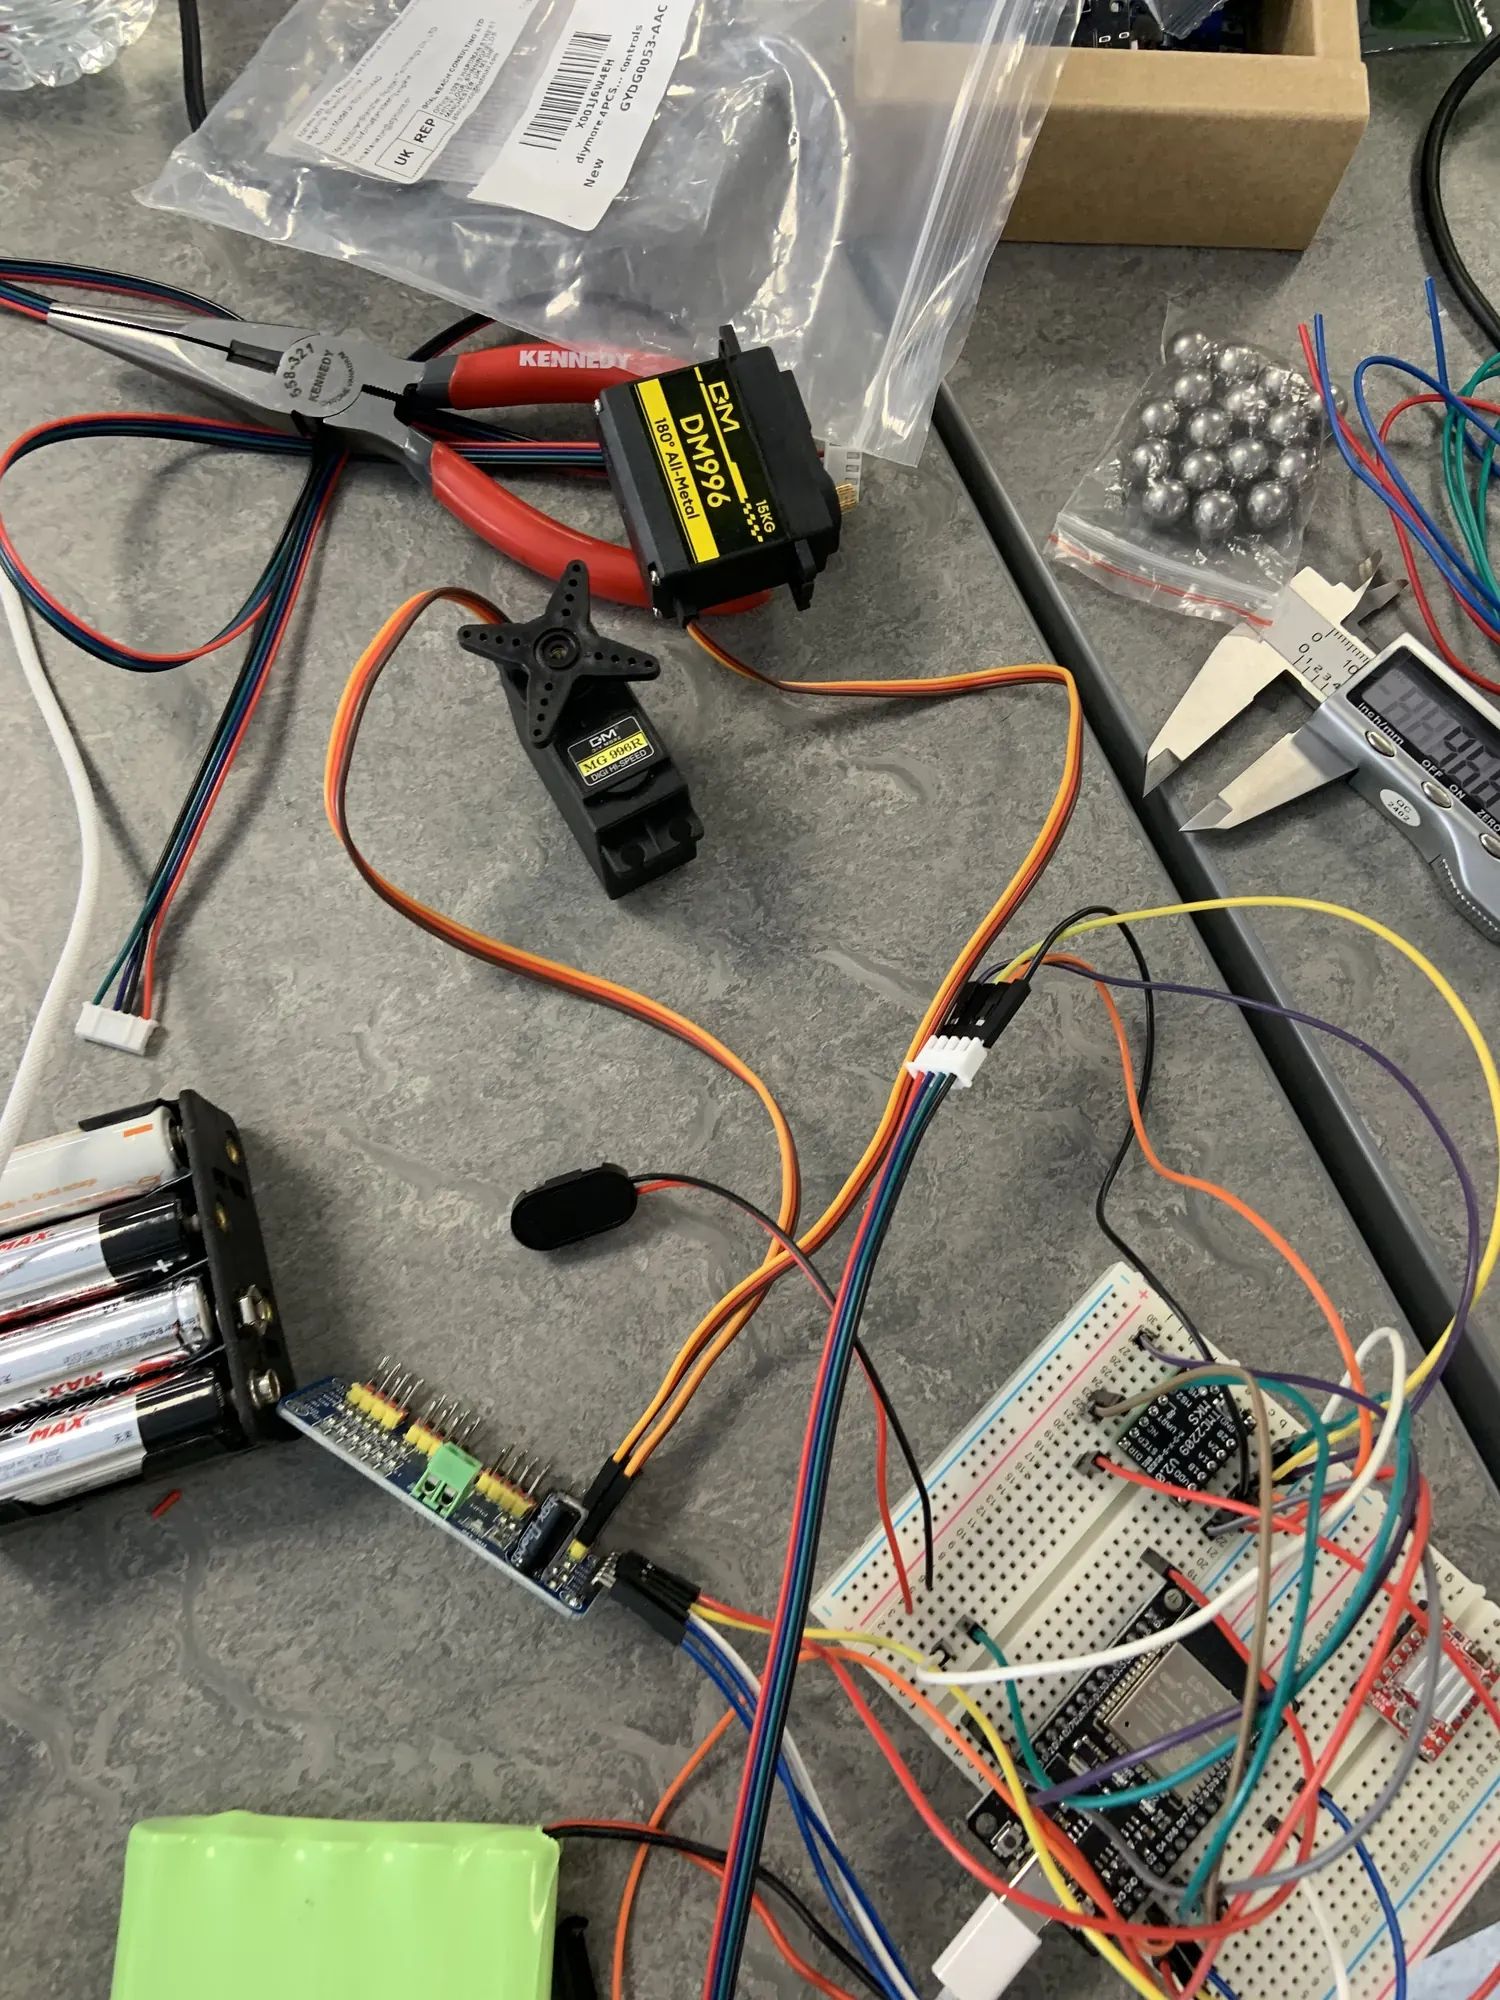
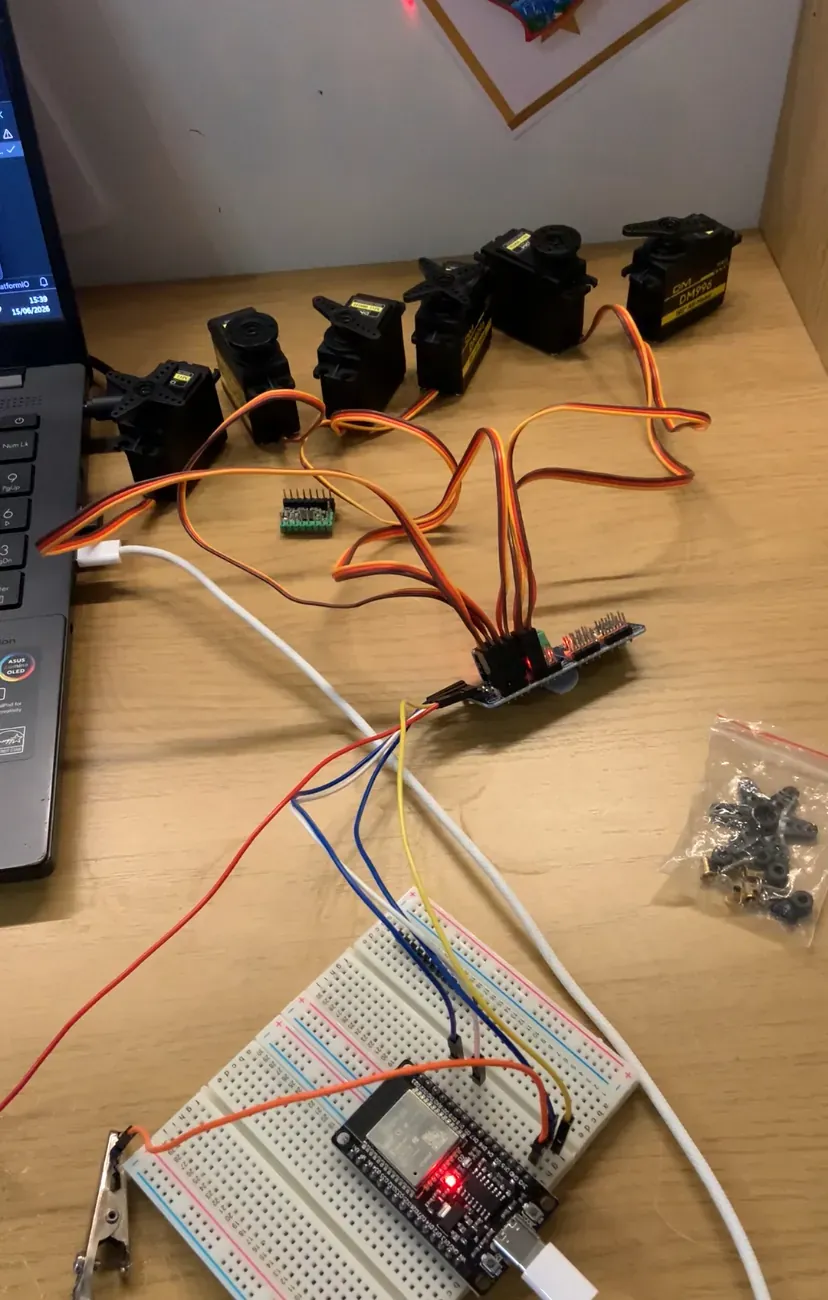
The arm is 3D printed and driven by servos through a custom controller. I developed it in stages, from a breadboard servo rig to a full arm on a test board, and fixed mechanical and electrical problems at each step.
02
Control & Vision
A machine-learning computer vision system finds each block and its colour. PID control drives each joint to its target, so the arm moves accurately and repeats its moves reliably.
Gallery · 8 Images
Next Project · 04Imperial Unibots →